Transport IDE
A modern Java- and JavaFX-based Intelligent Transportation Systems (ITS) modeling, discrete-event simulation, and control strategy optimization workbench.
Technology Readiness Level
Technology Validated in Lab
Key components and software architecture modules are integrated and tested together in a controlled laboratory environment, establishing that disparate elements work together to achieve baseline performance.
Framework alignment: Standardized 9-level TRL (NASA / EU Horizon Europe).
Core Challenge
Designing modern intelligent transportation systems requires evaluating interrelated decisions across physical road topology, charging infrastructure, fleet sizing, and dynamic dispatching strategies amidst complex stochastic demand.
System Architecture
A modular, model-based software workbench combining an extensible domain-specific editor, a low-overhead discrete-event simulation engine, and comparative benchmarking algorithms for autonomous vehicle fleets and on-demand mobility.
Key Capabilities
- Discrete-Event Simulation: Fast evaluation of on-demand transportation fleets by advancing time across domain-relevant milestones rather than continuous micro-steps.
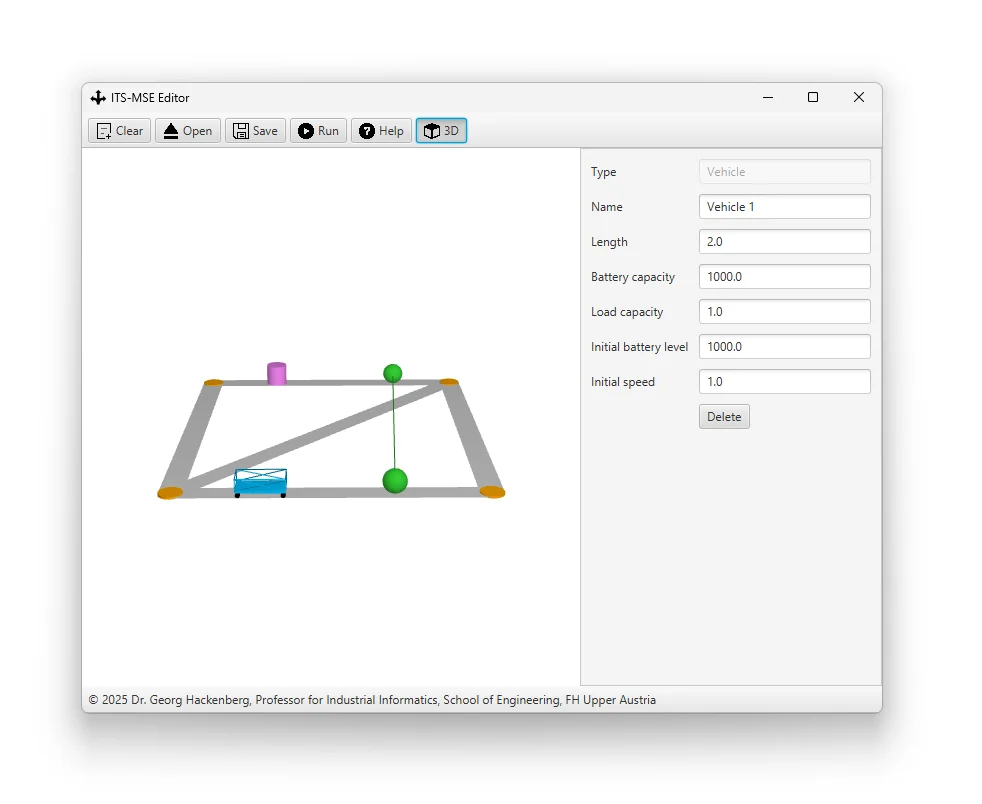
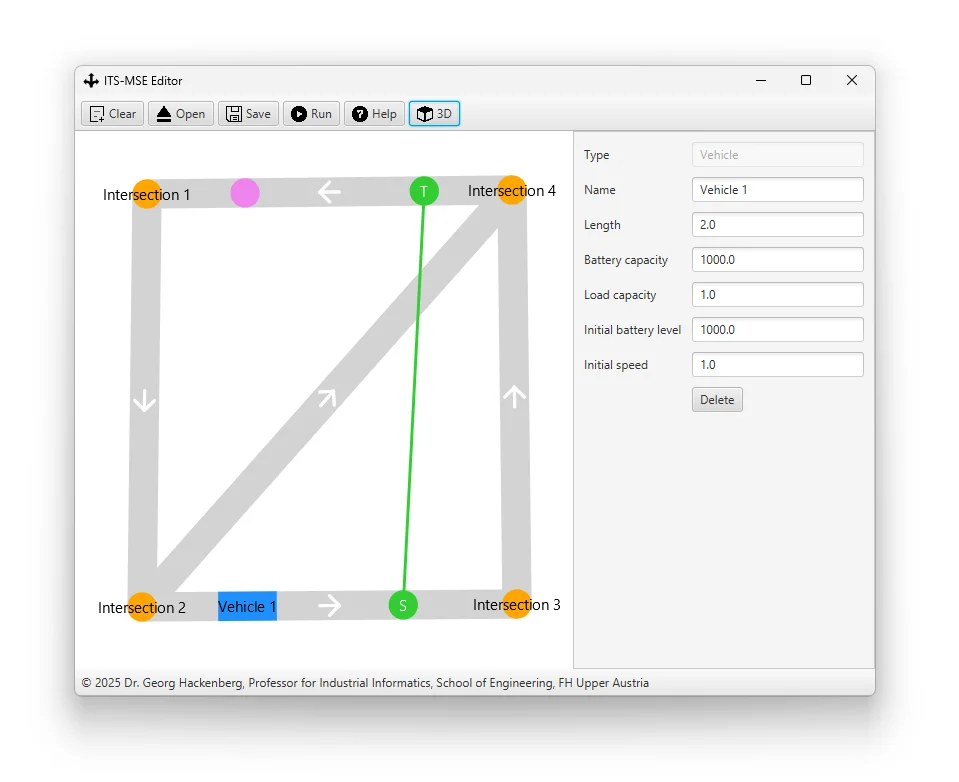
- Multi-Modal Network Modeling: Unified graph topology defining road segments, intersections, energy charging stations, and stochastic passenger demand pairs.
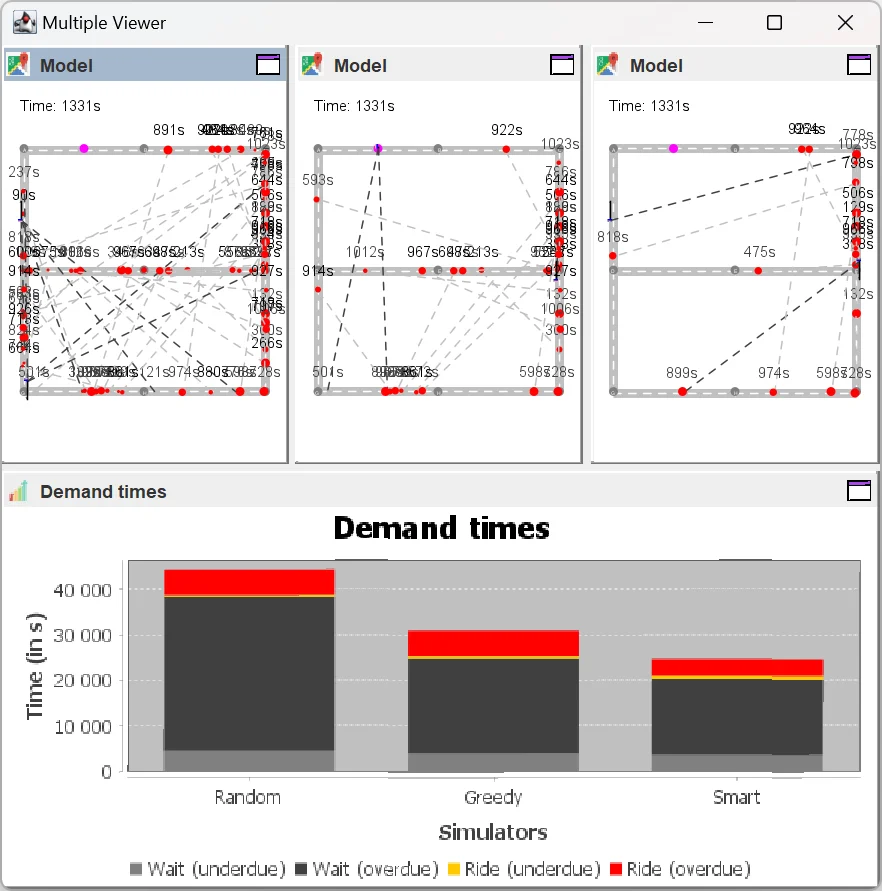
- Plug-and-Play Control Strategies: Pluggable dispatch and routing algorithms ranging from heuristic greedy solvers to approximate dynamic programming and shortest paths.
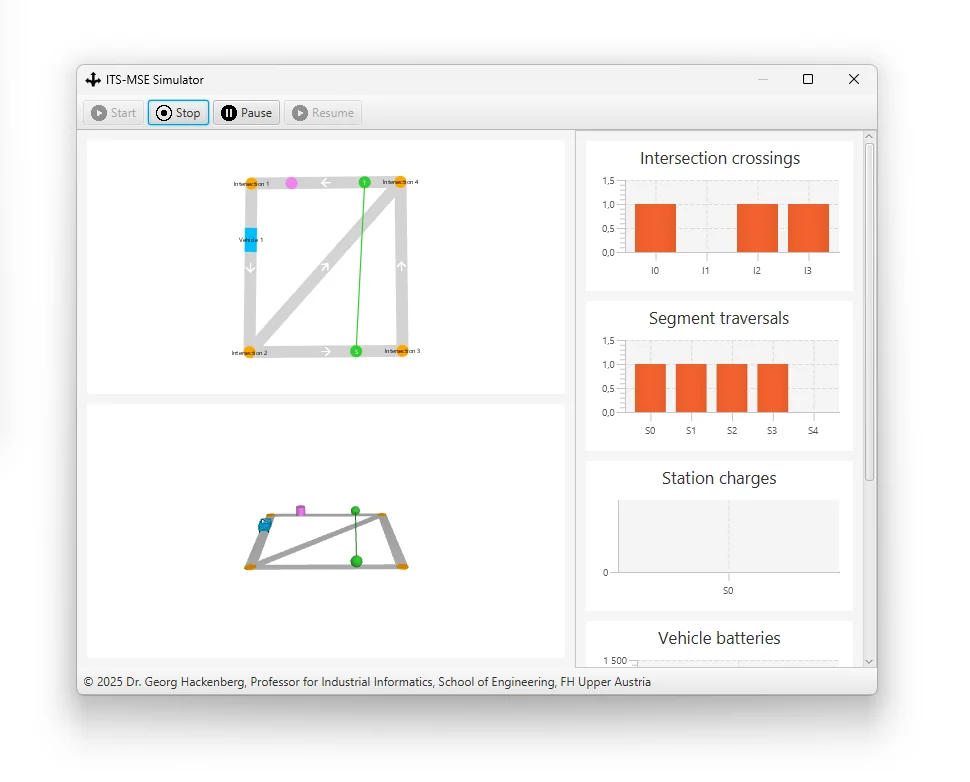
- Dual 2D/3D Visualization: Interactive JavaFX visualizer supporting both planar topological graphs and 3D spatial models with real-time telemetry charts.
- Monte-Carlo Experimentation: Multi-threaded batch execution and statistical aggregation to compare fleet performance, waiting times, and charging constraints.
Technology Stack
- Core & Architecture: Java 17+, Java Jigsaw Modules, Apache Maven, Discrete-Event Formalism
- GUI & Visualization: JavaFX, Java 3D / FX Canvas, Java Swing (Legacy Module)
- Optimization & Control: Approximate Dynamic Programming, Dijkstra Shortest Path, Monte-Carlo Simulation, Multi-Threaded Execution
Verifiable Outcomes
- Presented and published in peer-reviewed proceedings at MODELSWARD 2025, ISDA 2024, and IEEE ITSC.
- Orders-of-magnitude speedup over traditional continuous-time microscopic traffic simulators via discrete-event semantics.
- Fully open-source modular architecture under MIT license on GitHub (github.com/ghackenberg/Transport-IDE).